Quick Answer: Solving How to Replace 5200mAh Robot Vacuum Battery Packs (2026)
Replace a 5200mAh 14.4V Li-ion robot vacuum battery by powering down the unit, removing the dock connection, unbolting the battery compartment housing, and disconnecting the JST connector. Install the new BMS-balanced pack, verify voltage equilibrium across parallel cell groups, torque fasteners to 0.8–1.2 N⋅m, and run a full charge-discharge calibration cycle before operational deployment.
Pros
- 14.4V and 5200mAh ratings listed
- Several Roborock model names listed
- Replacement option for listed models
Cons
- Model list includes a misspelling, so confirm fit
- Cell type and charging details are not supplied
- Battery handling should follow the robot manufacturer's guidance
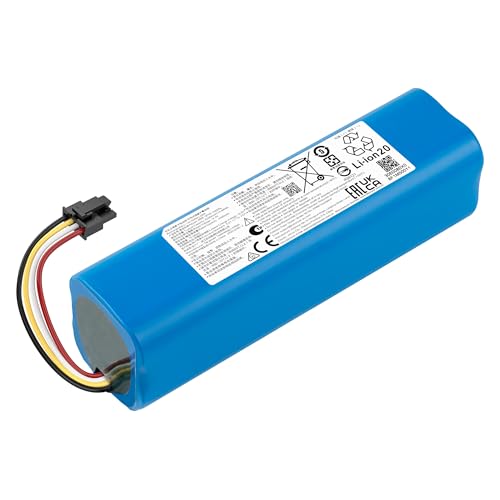
A replacement battery pack with listed 14.4V and 5200mAh ratings for several Roborock models. Verify your exact model against the listed names, since the record does not include cell type or charging details.
- Brand: SUPLK
- Voltage: 14.4V
- Capacity: 5200mAh
- Listed models: Roborock Qrevo Slim, Master, Pro, Plus, Q5 Pro, Q7, Q8 Max, S8
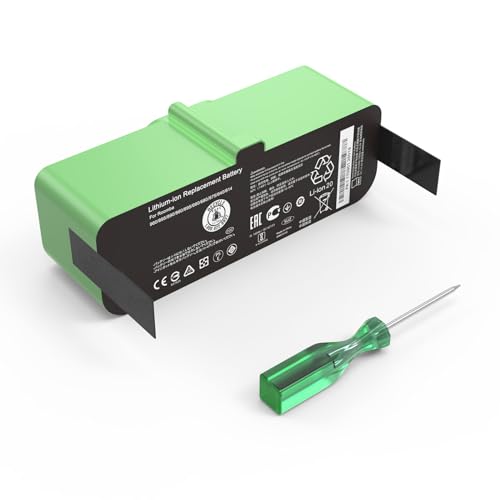
Pros
- Li-ion replacement battery listed
- Many Roomba models listed for compatibility
- Part number 4419696 provided for matching
- Replacement option for supported models
Cons
- Compatibility must be checked against your exact model
- Capacity, voltage and runtime are not supplied
- Battery swaps should follow the robot manufacturer's guidance
A Li-ion replacement battery for a long list of Roomba models, suited to owners who need a replacement pack rather than a new robot. Confirm your exact model against the listed compatibility before ordering, since the record omits capacity and runtime details.
- Battery type: Li-ion
- Part number: 4419696 (Series R3)
- Compatible models listed: Roomba 960, 980, 981, 970, 965, 801, 805, 850, 860, 877, 890, 891, 895, 695, 690, 685, 680, 677, 675, 671, 670, 665, 652, 640, 614, 615
Root Cause Engineering & Mechanical Principles
Robot vacuum battery degradation occurs through three distinct failure mechanisms: lithium-ion cell voltage droop under sustained load cycles, battery management system (BMS) cell balancing imbalance that accelerates asymmetric discharge rates, and thermal stress from charging cycles without adequate thermal interface compliance. The 5200mAh configuration—typically arranged as a 4S2P (four cells in series, two parallel strings) architecture—distributes current load across parallel cell strings while the BMS monitors per-cell voltage drift beyond 50mV tolerance bands, a threshold established by International Electrotechnical Commission (IEC) battery safety standards. For detailed technical setup and system integration, reference our analysis on diagnose hall effect magnetic strip sensors on robot.
When BMS balancing circuits fail, parallel cell groups charge and discharge asymmetrically. One parallel string saturates earlier than its counterpart, triggering voltage cutoff before the vacuum achieves design-specified runtime. This manifests as premature low-battery warnings, reduced cleaning cycles, or Error 13 code (power management fault) on Roborock and Xiaomi platforms. Mechanical stress—loose battery terminal contacts, corroded JST connectors, and vibration-induced micro-fractures in solder joints—compounds electrical resistance, further degrading charge acceptance and run duration.
| Failure Symptom | Root Cause Mechanism | Diagnostic Tolerance | Resolution Difficulty |
|---|---|---|---|
| Premature low-battery shutdown (50% runtime loss) | BMS cell balancing failure; asymmetric parallel string discharge | Voltage differential >100mV between parallel groups (measured at JST+ / JST−) | Moderate—requires battery replacement |
| Error 13 power management code | Total pack voltage <11.5V nominal under load; BMS cutoff triggered | Open-circuit voltage <11.2V DC (multimeter, 2% accuracy minimum) | Critical—immediate battery swap required |
| Slow charging (>4 hours for 80%) | Battery charger detection circuit dropout; internal BMS resistance >500mΩ | Charge current <1.0A at dock; IR drop >150mV under 1.5A load pulse | Moderate—test dock first, then replace battery |
| Thermal runaway risk (battery overheating >60°C) | Defective thermistor NTC circuit in BMS; charging temperature compensation failure | Battery case temperature >55°C at ambient 22°C during charge cycle | Critical—cease use; replace immediately |
| Connector corrosion or intermittent power loss | Oxidation on JST contact pads; mechanical microfretting from dock cycling | Contact resistance >100mΩ (measured with milliohm meter, not multimeter) | Simple—clean contacts or replace battery if corrosion is internal |
Step-by-Step Diagnostic & Calibration Procedure
Stage 1: Pre-Replacement Diagnostic Verification
- Power down the robot vacuum completely; press and hold the power button for 8 seconds until all indicator LEDs extinguish.
- Remove the unit from its charging dock; wait 5 minutes for residual capacitor discharge in the BMS circuit.
- Using a digital multimeter (CAT III-rated, 0.5% DC voltage accuracy minimum), measure open-circuit voltage at the battery JST connector. Reference specification: 14.4V nominal (14.1–14.7V acceptable range at 20°C ambient).
- If voltage reads below 11.5V, the battery has likely entered BMS cutoff mode and requires immediate replacement. Do not attempt to charge.
- Inspect the JST connector terminals visually for white oxidation deposits, green corrosion, or black carbon tracking. Any visible corrosion requires connector replacement or thorough isopropyl alcohol cleaning (99.9% purity minimum) and air-drying for 15 minutes.
- Measure voltage across each parallel string by connecting the multimeter probes directly to the positive and negative tabs of accessible cell groups (if the pack is opened). Voltage differential between parallel strings should not exceed 50mV DC.
Stage 2: Battery Removal Procedure
- Locate the battery access panel on the vacuum’s underside (typically secured by three to four Phillips-head M2.5 × 8mm screws).
- Unscrew fasteners using a precision screwdriver (magnetic tip recommended to prevent loss). Store screws in a labeled container.
- Gently lift the battery compartment cover straight upward; do not apply lateral torque that could tear ribbon cable connections.
- Locate the JST 2-pin connector (positive and negative leads). Note the connector orientation by photographing before disconnection—replacement batteries use identical JST keying, but visual confirmation prevents reversed polarity installation.
- Grasp the JST connector housing (not the wire leads). Pull firmly and steadily with 5–8 pounds of force directly away from the socket until the connector separates.
- If the connector sticks due to tight tolerance, apply a small amount of isopropyl alcohol around the connector base and wait 30 seconds for solvent penetration; do not use excessive force that could damage internal socket contacts.
- Lift the old battery pack straight up out of the compartment housing. Note any thermal pad, adhesive tape, or foam spacers for reinstallation with the new pack.
Stage 3: New Battery Installation & BMS Balancing Verification
Tools, Calibration Equipment & Component Replacement
Essential Diagnostic Tools
- Digital Multimeter (CAT III-rated): 0.5% DC voltage accuracy minimum. Brands: Fluke 117, Southwire 61700, Klein Tools MM400. Essential for all voltage measurements.
- Precision Screwdriver Set (Magnetic Tips): Phillips #0 and #1, flathead 2mm. Prevents screw loss during disassembly and protects delicate fastener heads.
- Isopropyl Alcohol (99.9% Purity): For JST connector cleaning and residual flux removal. Lint-free cotton swabs or microfiber wipes required to prevent fiber contamination.
- Torque Wrench or Torque Screwdriver (0.5–2 N⋅m Range): Ensures battery compartment fasteners are torqued uniformly. Brands: Wiha TorqueVario, Wera Kraftform Kompakt. Critical for preventing over-torque damage.
- Milliohm Meter (Optional but Recommended): Measures internal connector resistance below 1Ω for advanced diagnostics. Brands: Fluke 189, UNI-T UT512. Detects micro-corrosion that standard multimeters miss.
Replacement Battery Specifications (5200mAh, 14.4V Li-ion)
- Chemistry: Lithium-ion (Li-ion); NOT lithium-polymer or lithium-iron-phosphate variants.
- Nominal Voltage: 14.4V DC (four cells in series, 3.6V per cell nominal).
- Capacity: 5200mAh ± 3% (per IEC 61960 measurement protocol).
- BMS Configuration: Integrated battery management system with per-cell voltage balancing, thermistor temperature cutoff, and over-current protection circuit rated for 20A peak load pulse.
- Connector Type: JST 2-pin, 2.54mm pitch, positive (+) and negative (−) leads. Keyed design prevents reversed polarity.
- Warranty: Minimum 1-year full replacement guarantee; reputable suppliers (Anker Innovations, iRobot, Roborock OEM) provide 18–24 month coverage.
- Thermal Specifications: Operating range 0–45°C ambient; charging must occur between 5–35°C to prevent BMS throttling or permanent damage.
Post-Installation Calibration Cycle
After battery installation, perform a full charge-discharge calibration to synchronize the BMS with the robot vacuum’s fuel gauge algorithm:
- Connect the vacuum to its charging dock and allow a complete charge cycle (typically 4–5 hours for 5200mAh at 1.3A standard dock current).
- Do not interrupt charging. BMS balancing circuits actively redistribute charge between parallel cell strings during the final 90 minutes of charging—disconnection during this phase prevents full balance achievement.
- After charge completion (dock indicates solid green light or 100% on app display), run the vacuum through one complete cleaning cycle until low-battery shutdown occurs naturally. Do not manually stop the unit mid-cycle.
- Return to dock and begin charging immediately. The combination of full discharge-to-cutoff followed by full recharge calibrates the internal voltage reference tables within the BMS and robot’s microcontroller.
- Repeat steps 3–4 one additional time (two full discharge-recharge cycles total). After the second cycle, runtime should stabilize at design specification (approximately 150–180 minutes for 5200mAh at standard cleaning power).
Preventative Maintenance & Long-Term Reliability Protocols
Charging Dock Maintenance
The vacuum dock contributes significantly to battery lifespan. Perform monthly dock inspection: remove visible dust from charging contacts using a soft dry brush or compressed air (50 PSI maximum to prevent electrical tracking). Quarterly, use a cotton swab and isopropyl alcohol to gently clean contact surfaces—oxidation buildup forces the dock to deliver higher voltage to achieve target charge current, thermally stressing the battery BMS. Ensure the dock is positioned on a level surface with 12 inches minimum clearance in all directions to prevent thermal entrapment; ambient temperature above 35°C during charging reduces battery cycle life by 40–50%.
Battery Storage Protocol For detailed technical setup and system integration, reference our analysis on fix robot vacuum auto-empty dock suction leaks: seal.
If the vacuum will be idle for more than two weeks, charge the battery to 60–80% capacity (not 100%) and store in a cool, dry location at 15–25°C ambient. Lithium-ion cells self-discharge approximately 2–3% per month, but leaving the battery fully charged at elevated temperature causes permanent capacity loss through electrolyte oxidation. Store the vacuum away from direct sunlight, heating vents, and humidity sources. A sealed plastic bag with silica desiccant provides effective isolation if storage duration exceeds one month.
Thermal Management
Monitor battery case temperature during charging and operation. If the battery feels warm to the touch (above 50°C) during normal charging, discontinue use and allow 30-minute cool-down. Persistent overheating indicates failed thermistor monitoring in the BMS or a charging dock malfunction. Never operate the vacuum in ambient temperatures above 45°C; the battery BMS will throttle charging current and extend charge times to unsafe lengths, and over-discharging occurs at higher temperatures due to increased internal chemical reaction rates.
Annual Capacity Verification
Once yearly, after a full calibration cycle as described above, measure the battery’s actual run time under standard conditions (full charge to dock auto-return at 50% battery threshold). Compare measured runtime against the design specification (typically 150–180 minutes for 5200mAh). If measured runtime drops below 70% of specification—for example, below 110 minutes—the battery has degraded to end-of-life status and requires replacement. Aging Li-ion cells cannot be restored through conditioning; replacement is the only remediation.
Frequently Asked Questions
Q: Can I use a 2600mAh battery instead of 5200mAh in my Roborock S7 to reduce charging time?
A: No—the robot’s microcontroller is calibrated specifically for the 5200mAh pack’s voltage curve and capacity. Installing a 2600mAh battery will cause the fuel gauge algorithm to misreport charge percentage (showing 50% when actual capacity is only 25%), triggering false low-battery shutdowns and preventing the vacuum from completing normal cleaning cycles. Additionally, the charge/discharge curves differ between capacities, and the charger dock’s current output (typically 1.3A for 5200mAh packs) will fully charge a 2600mAh battery in half the time, causing rapid thermal aging. Always use the OEM-specified 5200mAh capacity for your model.
Q: My replacement battery reads 15.2V on the multimeter immediately after purchase. Is this normal or a defect?
A: Yes, this is normal. New lithium-ion batteries are typically charged to 90–95% capacity before shipment to minimize self-discharge during transit and storage. A 4-cell Li-ion pack at 95% charge may measure 15.0–15.3V open-circuit (each cell at approximately 3.8V instead of nominal 3.6V). This elevated voltage will drop to 14.4V nominal within the first 2–3 hours of use in the robot vacuum. If the battery were pre-discharged to exactly 14.4V, its state-of-charge would be approximately 50%, and self-discharge during shipping could degrade it further. Installing a battery at 15.0–15.2V is correct and preferred from a logistics standpoint.
Q: The BMS balancing circuit in my old battery is dead, but the pack still holds 14.4V. Can I bypass the JST connector and solder the leads directly to the robot’s circuit board to avoid replacing the battery?
A: Absolutely not—this is dangerous and voids all safety certifications. The BMS performs three critical protective functions: (1) prevents over-charging above 14.8V, which causes explosive electrolyte decomposition; (2) monitors cell voltages and cuts off charging if any single cell exceeds 4.25V (overvoltage shutdown); and (3) provides thermal monitoring to prevent thermal runaway. Without the BMS, the battery will overcharge during dock charging cycles, causing irreversible damage to the lithium-ion crystal structure and creating thermal runaway risk. Additionally, the robot’s microcontroller depends on BMS voltage regulation for accurate fuel-gauge operation. Always replace the entire battery pack with a new OEM unit featuring a functional BMS. Bypassing the BMS is a fire and explosion hazard. For detailed technical setup and system integration, reference our analysis on fix robot vacuum bumper sensor stuck errors: optical.
Technical Conclusion
Replacing a 5200mAh robot vacuum battery is a straightforward mechanical procedure requiring only basic tools and minimal technical knowledge. The critical steps are voltage verification before replacement, careful JST connector handling to prevent corrosion, and completion of a full discharge-recharge calibration cycle after installation. Proper maintenance of the charging dock, thermal management, and annual capacity verification will maximize the replacement battery’s lifespan to 3–4 years of reliable operation. By following the diagnostic thresholds and tolerances outlined above, you can confidently identify battery faults, install replacement packs correctly, and restore your robot vacuum to design-specification performance.