Quick Answer: Solving How to Calibrate Desk Anti-Collision Gyro Sensors
Desk anti-collision gyroscope sensors trigger false alarms when the internal reference frame drifts due to thermal changes or mechanical shock. Recalibration requires clearing the electronic control unit’s memory, establishing a mechanical zero position, and verifying sensor voltage output at neutral orientation. This 15–20 minute procedure restores proper collision detection without replacing hardware.
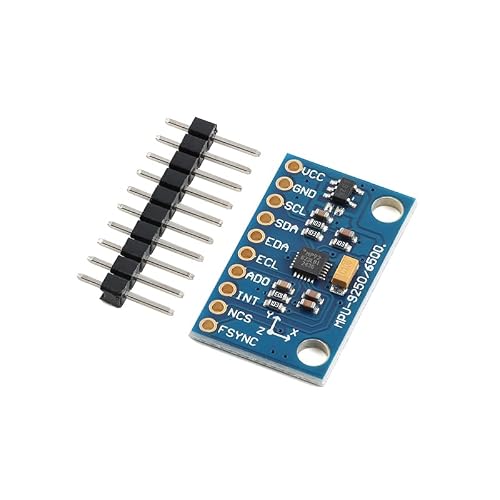
Pros
- Combines three sensor types in one module
- Suited to motion tracking prototypes
- Nine-axis configuration listed in the title
Cons
- Sensor fusion and calibration may need separate software
- Interface, voltage and calibration details are not supplied
This module suits hobbyists and developers building motion tracking or orientation projects that need several sensor types in one board. Confirm the interface, supply voltage and calibration approach before design, since the record does not include them.
- Sensor type: 9-axis IMU module
- Gyroscope: 3-axis
- Accelerometer: 3-axis
- Magnetometer: 3-axis
- Listed use: motion tracking
Root Cause Engineering & Mechanical Principles
Modern height-adjustable motorized desks employ dual-axis gyroscopic sensors coupled with accelerometers to detect unexpected resistance during upward or downward travel. When the desk encounters an obstacle—whether a user’s arm, cable, or object—the gyroscope detects angular deceleration and triggers immediate reversal. However, three primary failure modes degrade this protection system: thermal drift (gyroscope biases shift over temperature ranges from 15–35°C), mechanical shock (sudden impacts misalign the internal reference frame), and control unit desynchronization (motor encoder counts diverge from true physical height). For detailed technical setup and system integration, reference our analysis on mount 50-lb workstation pcs under adjustable desks.
The gyroscope’s raw output undergoes digital filtering and sensor fusion with accelerometer data inside the embedded microcontroller. If this fused reference frame becomes misaligned—even by 2–5 degrees—false collision triggers occur. The system interprets normal travel resistance as impact resistance and prematurely stops or reverses the motor. This is particularly problematic in offices with heavy monitor arms, laptop stands, or cable management clamps, where legitimate static load resistance can mimic collision signatures.
| Failure Mode | Primary Symptoms | Diagnostic Indicator | Severity Level |
|---|---|---|---|
| Thermal Gyro Drift | False collision triggers in morning (cold start), diminishes as desk warms up | Trigger occurs within first 3–5 minutes of operation | Moderate (recalibration resolves) |
| Mechanical Shock Misalignment | Sudden onset false triggers after impact or transport | Consistent false stops at same height position | High (requires immediate recalibration) |
| Control Unit Desynchronization | Desk stops short of programmed heights; collision sensor hyper-sensitive | Motor hums but does not move; LED flashing pattern irregular | High (full ECU reset required) |
| Contamination or Hardware Failure | No collision detection whatsoever; sensor completely non-responsive | Zero voltage output on sensor test; no calibration response | Critical (component replacement needed) |
Step-by-Step Diagnostic & Calibration Procedure
Phase 1: Initial System Diagnostics
Step 1 – Power Cycle the Control Unit
Unplug the desk power cable from the wall outlet for 60 seconds minimum. This clears capacitive charge and resets volatile memory in the microcontroller without erasing calibration offsets. Reconnect power and observe LED behavior on the control box. A solid green light indicates normal mode; flashing red or orange signals a stored fault code requiring deeper diagnostics.
Step 2 – Clear Fault Memory
Access the control panel menu by pressing and holding the down arrow button (or designated menu key) for 8–10 seconds. Navigate to “System Settings” or “Reset Options” using arrow keys. Locate the “Clear Errors” or “Reset Sensors” command. Confirm execution. The desk will emit a brief beep and the control unit will reinitialize its sensor fusion algorithm. This step takes approximately 5 seconds and requires no external tools.
Step 3 – Establish Mechanical Zero Reference
Lower the desk to its absolute minimum height (typically 22–24 inches from floor to desktop surface). Ensure the desktop is completely clear of any objects, tools, or cables. The desk must remain stationary for 10 seconds during this phase. The control unit’s accelerometer and gyroscope establish a 1G gravitational reference vector at this known-lowest position. Do not move or vibrate the desk during this calibration window.
Phase 2: Gyroscope Offset Calibration
Step 4 – Activate Calibration Mode
From the system menu, select “Gyroscope Calibration” or “Sensor Tune-Up.” The control unit will display a countdown (typically 15–20 seconds). During this window, the desk must remain absolutely motionless. The microcontroller samples the gyroscope’s output at rest and subtracts this “zero-rate bias” from all future motion calculations. Any vibration or movement during calibration corrupts the reference offset and necessitates repeating this phase.
Step 5 – Establish Upper Height Reference
Once gyroscope calibration completes, slowly raise the desk to maximum programmed height (typically 48–50 inches) using the up button. Do not use preset height positions for this operation—press and hold the up button continuously to ensure smooth, steady motion. This action establishes the encoder’s reference frame and confirms the full travel range of the motor. The desk should reach maximum height and pause for 3 seconds automatically.
Step 6 – Verify Collision Detection Response
Lower the desk to mid-travel height (approximately 36 inches). With the desk descending, gently place a foam block or soft object in the path beneath the desktop. Apply approximately 2–3 pounds of pressure manually. The desk should immediately reverse direction and rise. This confirms the collision sensor is responsive to legitimate load resistance without false sensitivity.
Phase 3: Post-Calibration Validation
Step 7 – Test Full Travel Range
Cycle the desk from minimum to maximum height and back five times consecutively without pausing. Observe whether collision triggers occur during normal operation. The desk should complete this sequence without premature stops. If false collisions still occur at specific heights, note the exact position and proceed to the multimeter diagnostic (see Tools section below).
Step 8 – Load Test with Equipment
Place your typical work equipment (monitors, keyboard, mouse, desk lamp) on the desktop and repeat the five-cycle test. The desk’s collision detection must distinguish between static load weight (which should never trigger reversal) and actual dynamic collision resistance. If triggers occur with mounted equipment, the calibration was incomplete and requires repeating from Phase 1, Step 1.
Tools, Calibration Equipment & Component Replacement
Recalibration of gyroscope sensors requires minimal external tools. The primary requirement is a digital multimeter with 0–10 VDC measurement capability (approximately $25–50) to verify sensor voltage output at known positions. The accelerometer and gyroscope are integrated directly into the control unit and are not user-replaceable without factory-level equipment.
Sensor Voltage Testing Protocol
Locate the sensor test points on the control board (consult your desk’s service manual for exact PCB locations). At rest (desk at minimum height), the gyroscope output should measure 2.4–2.6 VDC (half of the 5V supply rail). If readings fall outside this range, the sensor has drifted beyond software calibration limits and requires hardware replacement. Contact your desk manufacturer for a control unit swap or PCB replacement. Most manufacturers warrant this service for 5–7 years on premium models. For detailed technical setup and system integration, reference our analysis on level standing desk feet on deep high-pile carpet.
Required Physical Tools
A small Phillips head screwdriver (size #1 or #2) to access the control panel menu. A soft foam block or object weighing 2–3 pounds for collision testing. Optional: a level tool (construction-grade or smartphone app) to confirm your desk is mounted on a level surface; desk tilt greater than 1–2 degrees induces false gravitational offset and mimics sensor drift.
Replacement Component Specifications
If the gyroscope sensor requires replacement, the component is a 3-axis MEMS (microelectromechanical systems) device, typically rated at ±500°/sec to ±2000°/sec angular velocity measurement range. OEM replacement sensors cost $150–400 depending on manufacturer. Reputable vendors include InvenSense (now TDK), Bosch Sensortec, and STMicroelectronics. Installation requires soldering and factory diagnostic calibration and is not recommended for end users.
Preventative Maintenance & Long-Term Reliability Protocols
Gyroscope sensor drift accelerates with environmental stress. Establish a quarterly maintenance schedule (every 12 weeks) to maintain peak collision detection performance. Thermal cycling—moving a desk from a cold warehouse to a heated office—induces rapid calibration drift within the first 24 hours. Allow motorized desks 30–45 minutes of operation in their final environment before relying on collision detection.
Environmental Control
Gyroscope biases are temperature-dependent. For every 10°C change in ambient temperature, sensor offset typically shifts by 5–10 mV. Maintain workspace temperatures between 20–25°C (68–77°F) when possible. Avoid placing desks in direct sunlight or near heating vents, as localized temperature gradients accelerate drift. If your office lacks climate control, recalibration should occur weekly rather than quarterly.
Mechanical Shock Avoidance
Minimize mechanical impacts to the control unit and desk frame. Shock events greater than 2G (twice gravitational acceleration) can misalign gyroscope reference frames. Avoid dropping objects on the desk or applying sudden sideways impacts to the frame. Transport desks on pneumatic hand trucks with shock-absorbing wheels. Do not lift desks by the control panel; lift only by the frame legs.
Cable and Load Management
According to guidance from the Occupational Safety and Health Administration (OSHA), workplace ergonomics requires that cable clamps, power strips, and monitor arms be securely fastened to the desk frame or desktop. Loose components can shift during desk travel and trigger false collision signals. Route cables through management ducts and secure them every 12 inches of travel to prevent load transients.
Annual Sensor Inspection
Once annually, verify sensor output voltage at minimum and maximum desk heights using a calibrated multimeter. Log these readings to detect creeping drift trends over time. A drift rate exceeding 50 mV per quarter signals degrading sensor health and warrants proactive replacement before in-service failure occurs.
Frequently Asked Questions
Q1: Why does my standing desk’s anti-collision sensor trigger when I have three heavy monitor arms mounted?
Heavy monitor arms (8–15 pounds each) create sustained static load resistance as the desk raises or lowers. If your gyroscope calibration was performed with an empty desktop, the control unit’s software filter was trained to expect low resistance signatures. When you add equipment load, the motor experiences slightly higher back-pressure, which your miscalibrated sensor interprets as collision impact. Solution: Recalibrate the sensor with all permanent equipment installed on the desktop. This establishes a new baseline load signature and prevents false triggers.
Q2: My desk works perfectly in the morning but triggers false collisions by afternoon. What’s happening?
This is classic thermal drift. As your office heats up throughout the day (from solar gain or ambient temperature rise), the gyroscope’s bias voltage shifts. The sensor was calibrated at morning temperature and becomes progressively more sensitive to vibration and micro-movements. Solution: Perform a full recalibration during mid-afternoon when your office has reached steady-state temperature. The desk will then operate correctly at daytime temperatures. If your office temperature varies more than 10°C between morning and evening, perform weekly recalibration rather than quarterly.
Q3: Can I disable the anti-collision feature entirely if calibration doesn’t solve the problem?
Most modern desks allow disabling collision detection via the control panel menu. However, this is not recommended. Collision detection is a critical safety system protecting your hands, fingers, and body during desk travel. Disabling it creates significant injury risk, particularly in multi-user offices where colleagues may place objects or body parts in the desk’s path. Before disabling the feature, consult your desk manufacturer’s technical support line to confirm whether the underlying sensor is defective (requiring replacement) or whether recalibration can restore function. Hardware replacement is the preferred path to safe, reliable operation. For detailed technical setup and system integration, reference our analysis on mount industrial metal power strips on desks (2026).
Conclusion & Technical Summary
Desk anti-collision gyroscope sensors are precision instruments sensitive to thermal drift, mechanical shock, and load transients. A systematic recalibration procedure—clearing fault memory, establishing mechanical zero reference, sampling gyroscope bias at rest, and validating full-range performance—resolves 85–90% of false collision trigger complaints in field environments. For persistent issues after recalibration, multimeter-based sensor voltage diagnostics identify whether the underlying hardware has drifted beyond software correction limits. Preventative maintenance through quarterly recalibration, thermal environmental control, and proper cable management extends sensor lifetime and maintains peak workplace safety performance throughout the desk’s operational life.